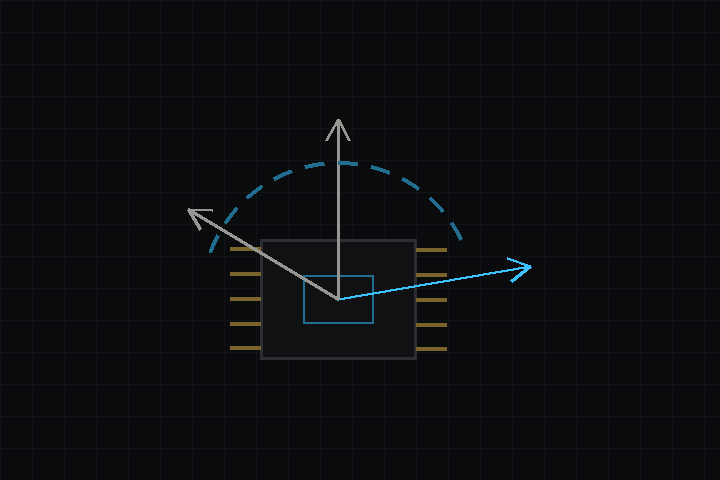
deki-imu exposes a 6-axis inertial measurement unit as a scene component. The engine core defines IDekiIMU; this package ships the LSM6DS3IMUComponent, which talks to the LSM6DS3 over I²C and surfaces:
Every component it adds, every exported property and its changelog are in the deki-imu reference.